સંકેત e^(−at) sin(ωt) એક વાસ્તવિક રેખીય સમય-અચલ પ્રણાલીનો ઇનપુટ છે. K અને ∅ અચળાંકો હોય, તો પ્રણાલીનો આઉટપુટ Ke^(−bt) sin(vt + ∅) સ્વરૂપનો થશે. નીચેનામાંથી સાચું વિધાન __________ છે
 જવાબ અને પગલાવાર ઉકેલ
C — b = a અને v = ω. અવમંદિત સાઇનસોઇડ e^((−a+jω)t)નો કાલ્પનિક ભાગ છે, જે LTI પ્રણાલીનું આઇગન વિધેય છે; પ્રણાલી ફક્ત સંકર ગેઇન (કંપવિસ્તાર અને કળા) બદલે છે, ક્ષય દર અને આવૃત્તિ નહીં.
વિગતવાર ઉકેલ (મૂળ ભાષામાં)
Concept & Reasoning
Write the input as Im{e^{(-a+jω)t}}. If the system has transfer function H(s), the response to e^{st} is H(s)e^{st} whenever the eigenfunction condition applies. H(-a+jω) contributes a constant magnitude K and phase φ. Thus the output form is Ke^{-at}sin(ωt+φ), giving b=a and v=ω.
How to Solve It in the Exam
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Important Exam Point
Recognize damped sinusoids as conjugate complex exponentials.
Editorial / Answer-Key Note
The official GPSC final answer key revised the provisional outcome for this question from A to C.
Quick Trick
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Common Mistake
Assuming the system can arbitrarily change frequency while remaining LTI under this eigenfunction setting.
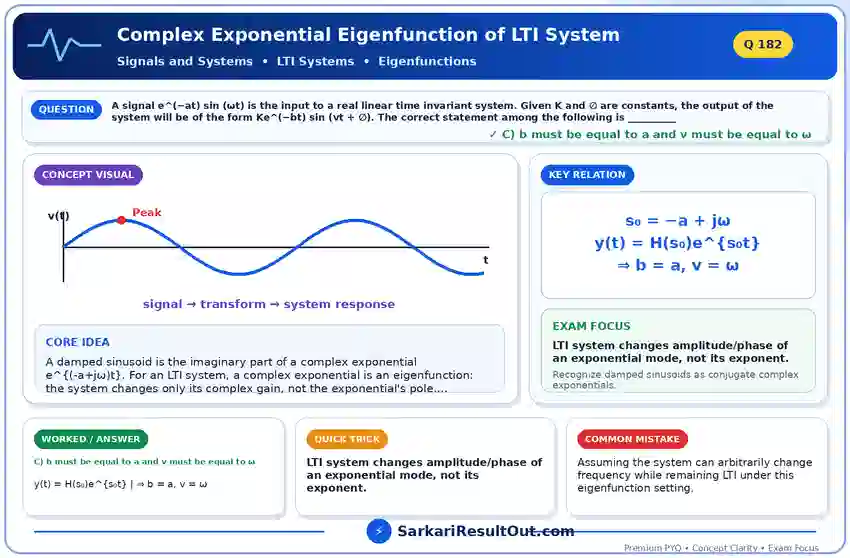
A signal e^(−at) sin (ωt) is the input to a real linear time invariant system. Given K and ∅ are constants, the output of the system will be of the form Ke^(−bt) sin (vt + ∅). The correct statement among the following is __________
Answer & step-by-step solution
A damped sinusoid is the imaginary part of a complex exponential e^{(-a+jω)t}. For an LTI system, a complex exponential is an eigenfunction: the system changes only its complex gain, not the exponential's pole. Therefore the output retains the same decay rate a and angular frequency ω; only magnitude and phase change.
Concept & Reasoning
Write the input as Im{e^{(-a+jω)t}}. If the system has transfer function H(s), the response to e^{st} is H(s)e^{st} whenever the eigenfunction condition applies. H(-a+jω) contributes a constant magnitude K and phase φ. Thus the output form is Ke^{-at}sin(ωt+φ), giving b=a and v=ω.
How to Solve It in the Exam
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Important Exam Point
Recognize damped sinusoids as conjugate complex exponentials.
Editorial / Answer-Key Note
The official GPSC final answer key revised the provisional outcome for this question from A to C.
Quick Trick
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Common Mistake
Assuming the system can arbitrarily change frequency while remaining LTI under this eigenfunction setting.
संकेत e^(−at) sin(ωt) एक वास्तविक रैखिक समय-अपरिवर्ती प्रणाली का इनपुट है। K और ∅ स्थिरांक हों, तो प्रणाली का आउटपुट Ke^(−bt) sin(vt + ∅) के रूप का होगा। निम्नलिखित में से सही कथन __________ है
उत्तर और चरणबद्ध हल
C — b = a और v = ω। अवमंदित साइनसॉइड e^((−a+jω)t) का काल्पनिक भाग है, जो LTI प्रणाली का आइगेनफलन है; प्रणाली केवल सम्मिश्र लाभ (आयाम और कला) बदलती है, क्षय दर और आवृत्ति नहीं।
विस्तृत हल (मूल भाषा में)
Concept & Reasoning
Write the input as Im{e^{(-a+jω)t}}. If the system has transfer function H(s), the response to e^{st} is H(s)e^{st} whenever the eigenfunction condition applies. H(-a+jω) contributes a constant magnitude K and phase φ. Thus the output form is Ke^{-at}sin(ωt+φ), giving b=a and v=ω.
How to Solve It in the Exam
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Important Exam Point
Recognize damped sinusoids as conjugate complex exponentials.
Editorial / Answer-Key Note
The official GPSC final answer key revised the provisional outcome for this question from A to C.
Quick Trick
LTI system changes amplitude/phase of an exponential mode, not its exponent.
Common Mistake
Assuming the system can arbitrarily change frequency while remaining LTI under this eigenfunction setting.
 More LTI Systems & Convolution questions